AdaTerrainDiff: Terrain-Conditioned Adaptive Action Refinement for Unified Bipedal Locomotion
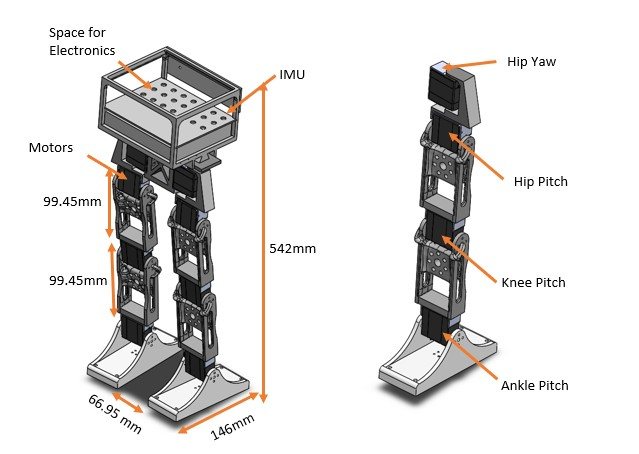
Ongoing work · 2nd-generation biped · IIT Mandi
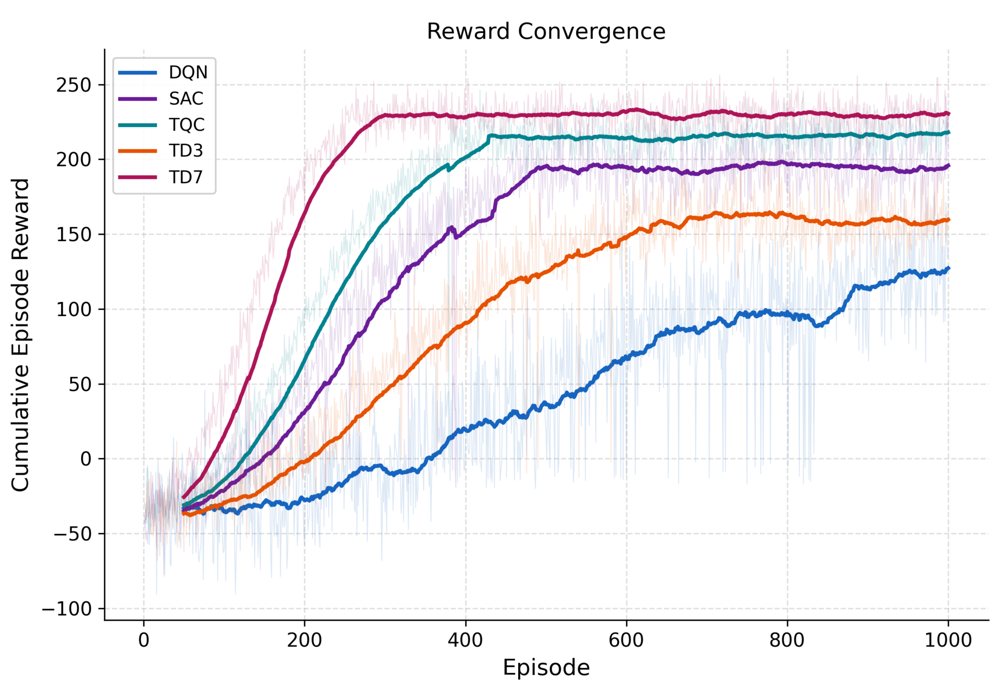
Diffusion-based locomotion controllers such as BiRoDiff and DiffuseLoco use one mixed latent and a fixed number of denoising steps, so they treat every terrain the same. AdaTerrainDiff splits the encoder into a 128-D state latent and a 16-D terrain latent built from the height map. The terrain latent then sets the action generation: 5 denoising steps on flat ground and up to 10 on stairs, with stochasticity scaled to the terrain. An x0-prediction denoiser stays stable with only a few steps, and the policy is trained with online PPO.
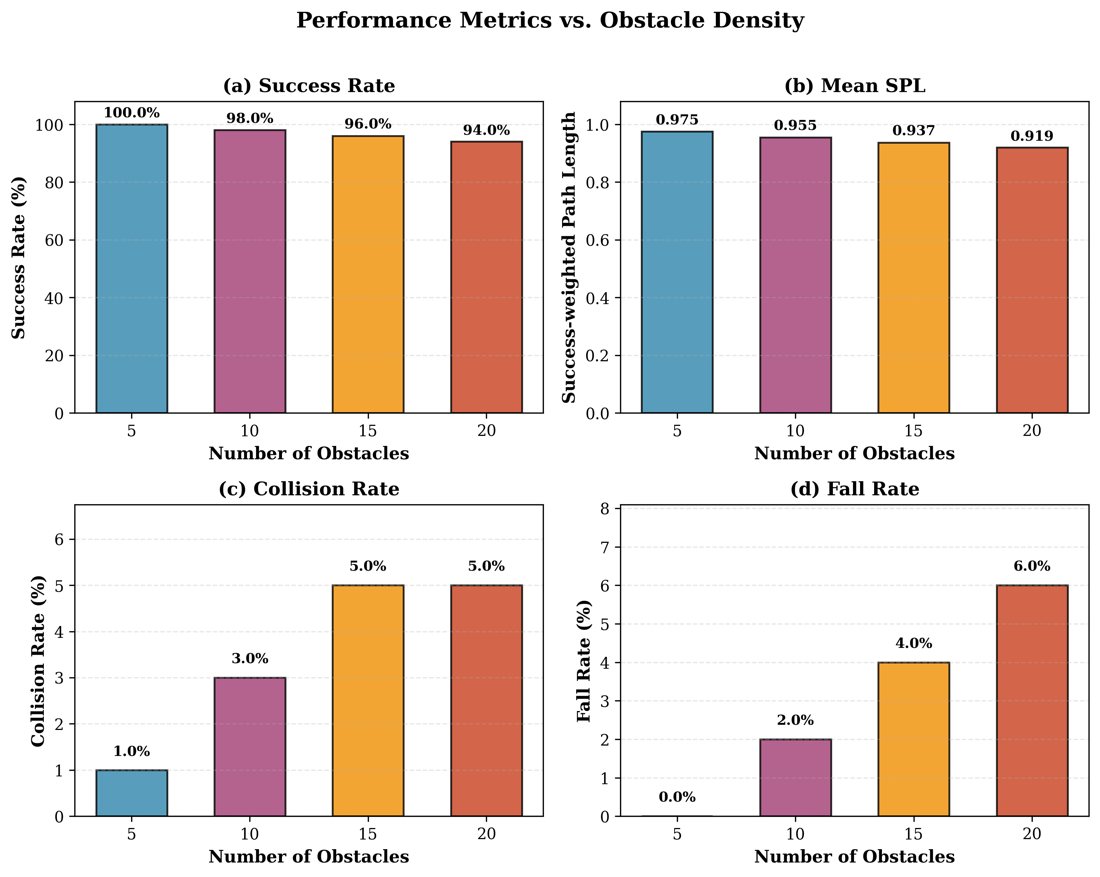
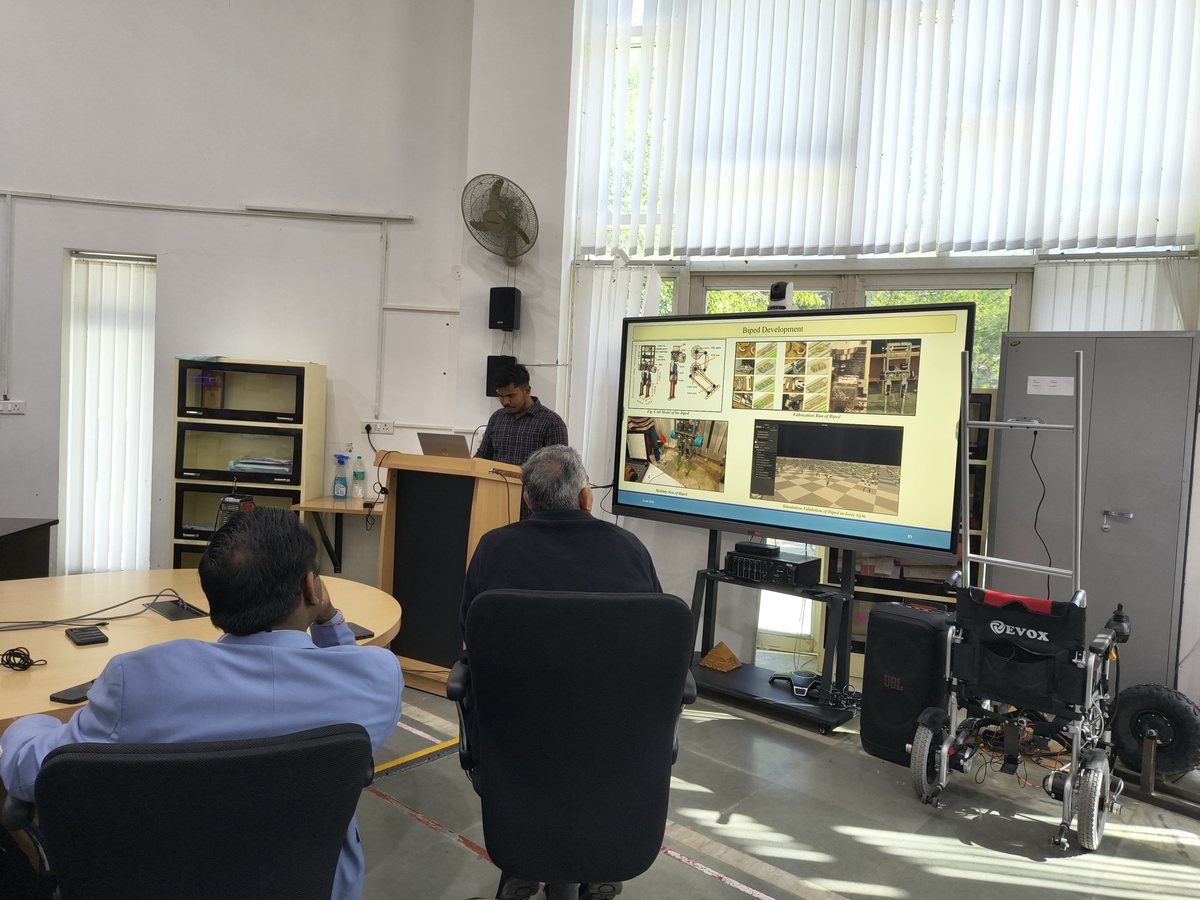
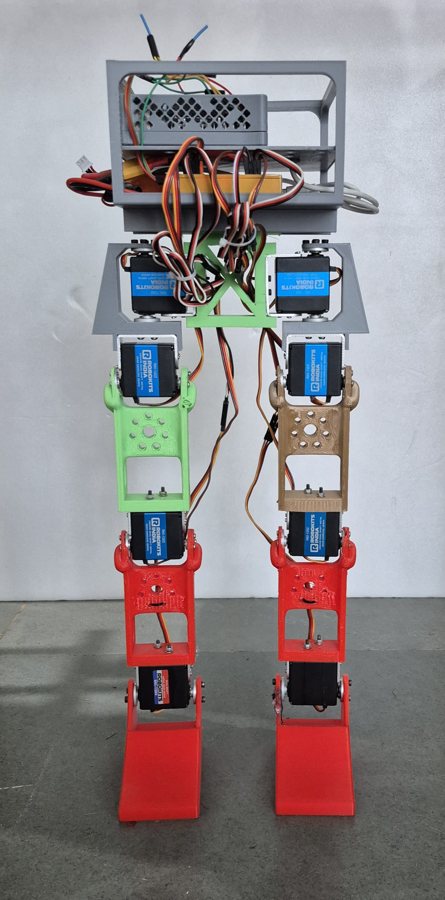
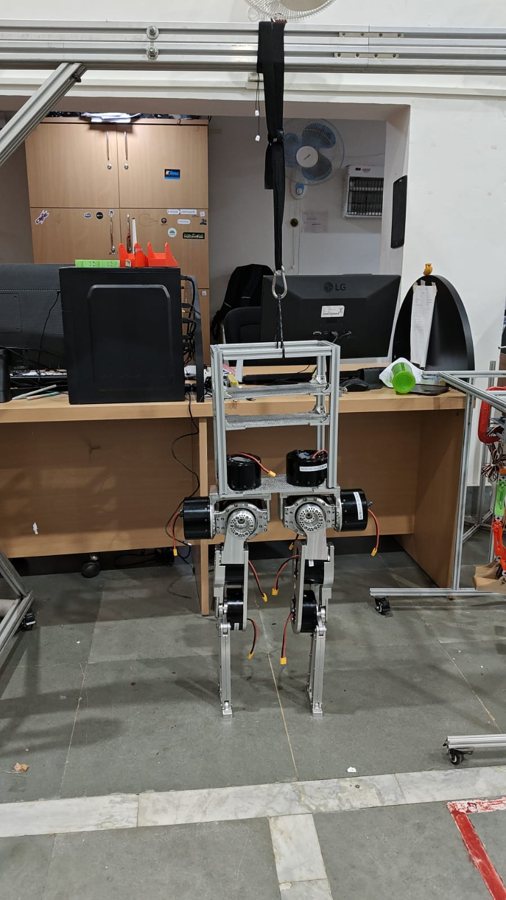
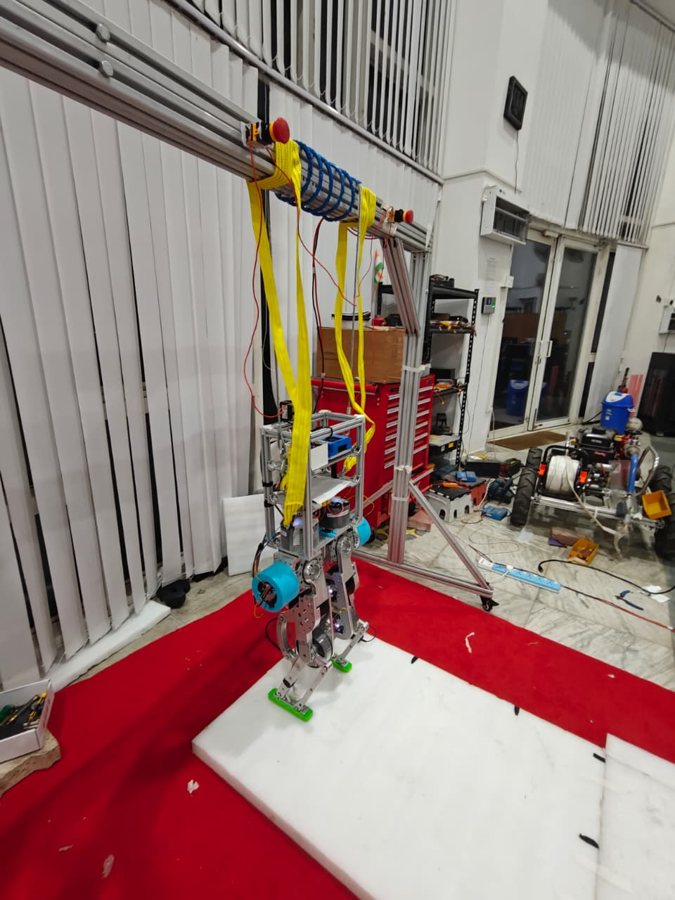
One policy walks on flat ground, slopes, rough terrain, discrete obstacles and stairs. Averaged over all terrains it reaches 81.0% success, versus 78.0% for BiRoDiff and 32.1% for DiffuseLoco. The biggest gains are on discrete terrain (+12 points) and steep slopes (+5.2 points). On the 10-DOF hardware biped, sim-to-real trials completed 98.3% of each 60-second episode, with cost of transport within 13% of simulation.